


Autonomous Mobile Robots in Manufacturing: Complete Guide to Factory Material Handling
Manufacturing is becoming increasingly automated, connected, and data-driven. Production lines now use technologies such as robotic assembly systems, automated inspection equipment, advanced SMT machines, Manufacturing Execution Systems (MES), and real-time production monitoring. Yet one critical activity between these automated processes often remains surprisingly manual: moving materials from one point of the factory to another.
Raw materials must reach production lines. Components need regular replenishment. Work-in-progress (WIP) must move between assembly, inspection, testing, and packaging. Finished goods must eventually reach storage or dispatch. In many facilities, employees still perform these repetitive movements using manually pushed trolleys and carts. The existing manufacturing process may therefore be highly automated, while the logistics connecting individual processes continues to depend on human intervention.
This is where Autonomous Mobile Robots for Material Handling are becoming increasingly relevant. Instead of assigning skilled production personnel to repetitive transportation, manufacturers can use AMRs to create a more predictable flow of materials between departments, production lines, warehouses, and workstations.
For Indian manufacturers pursuing higher productivity, lean manufacturing, Industry 4.0, and more scalable production, improving factory intralogistics automation is becoming an important part of the larger automation strategy. The objective is not simply to replace a trolley with a robot. It is to ensure that the right material reaches the right process at the right time without unnecessarily interrupting production personnel.
Why Material Movement Is the Hidden Bottleneck in Modern Manufacturing
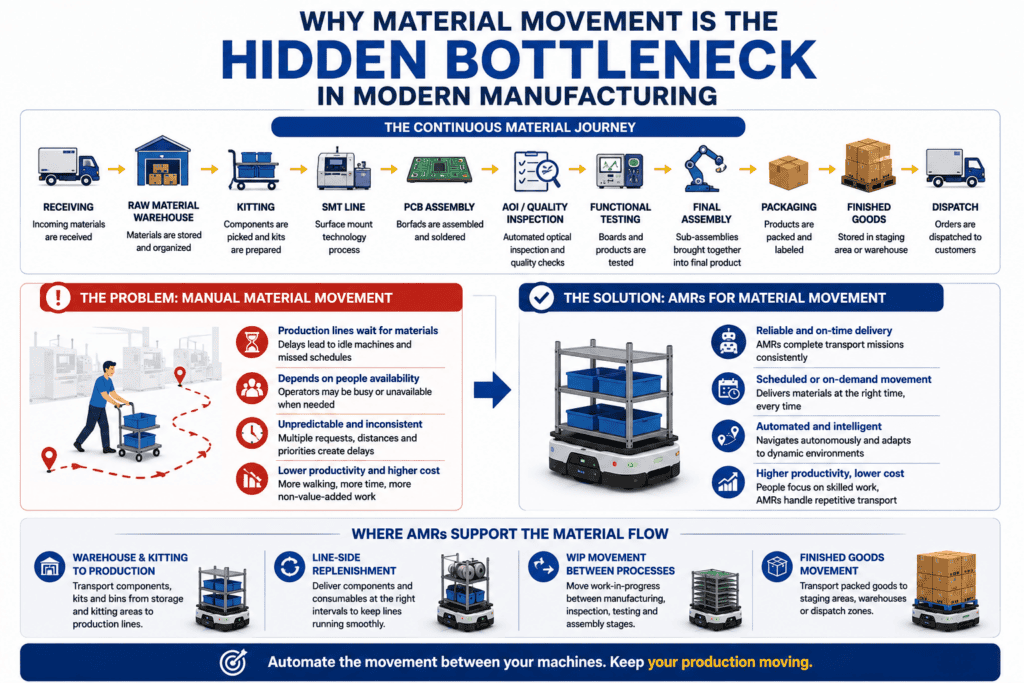
A factory can contain highly sophisticated production equipment and still lose valuable time because a component, production kit, tool, or WIP batch has not reached the next process when required.
This is because manufacturing depends not only on what happens inside individual machines, but also on what happens between those machines.
Consider the material journey through a typical manufacturing facility. Incoming materials move from receiving to storage. Components travel from warehouses to kitting areas and production lines. WIP passes through assembly, inspection, testing, and subsequent manufacturing stages. Packaging materials must reach the appropriate stations, while finished products need to move towards warehouses and dispatch areas. The existing blog correctly identifies this continuous internal flow as fundamental to manufacturing operations.
When these movements depend heavily on manual transportation, seemingly small delays can accumulate across an entire shift.
The result is an important distinction:
Production automation improves how products are manufactured. Material handling automation improves how efficiently materials move between those manufacturing processes.
Autonomous Mobile Robots for Material Handling address the second part of this equation by automating repetitive point-to-point transportation and creating a more structured approach to internal material movement in manufacturing.
Production Interruptions Caused by Material Delays
Production equipment can only operate efficiently when the required material is available when needed.
A production line waiting for a component kit, PCB magazine, raw material, consumable, or WIP batch is not necessarily experiencing a manufacturing-equipment problem. The underlying issue may instead be an internal logistics delay.
With manual material movement, delivery frequently depends on several variables: whether an operator is available, whether a trolley is ready, how far the pickup location is from the production line, and whether other transportation requests are already pending.
As these dependencies increase, material movement becomes less predictable.
The original blog identifies several potential consequences, including idle production lines, delayed line replenishment, increased WIP inventory, missed production schedules, and reduced Overall Equipment Effectiveness (OEE).
This is particularly important in high-throughput manufacturing environments. A short material delay may appear insignificant when considered as an individual event. When similar delays occur repeatedly across multiple production lines, departments, and shifts, however, their cumulative effect can become substantial.
Deploying Autonomous Mobile Robots for Material Handling in manufacturing plants creates the possibility of assigning these repetitive movements to an automated transport system instead of waiting for personnel to become available.
Unpredictable Internal Logistics
Manual material handling is also inherently dependent on people being available at the exact time transportation is required.
An operator may already be performing another production activity. Warehouse personnel may be processing another material request. Multiple departments may require replenishment simultaneously. Shift changes, breaks, or sudden production requirements can further influence material availability.
This can turn internal logistics into a reactive process:
Material is required → someone identifies the requirement → an available person must be found → material is collected → trolley is moved → delivery is completed.
The production line therefore becomes indirectly dependent on the availability of the person performing the transport.
Autonomous Mobile Robots for Material Handling allow manufacturers to approach the same process differently. Repetitive transport missions can be assigned to robots, while production and warehouse personnel remain focused on their primary responsibilities.
This does not eliminate the human role in manufacturing. Instead, it creates a clearer division of work: people manage activities requiring skill, judgement, quality control, decision-making, and process expertise, while AMRs perform repeatable transportation tasks.
Excessive Non-Value-Added Activities: The Hidden Cost on the Factory Floor
One of the most important reasons to examine factory material movement is its relationship with non-value-added activity.
From a lean manufacturing perspective, not every activity that consumes time contributes directly to transforming the product in a way that creates customer value. Internal transportation may be operationally necessary, but excessive movement can consume substantial employee time without directly contributing to manufacturing output.
This distinction is particularly important when production operators themselves are performing the transportation.
An employee may leave a workstation, locate a trolley, travel to a storage or staging area, collect materials, push them across the factory, complete the delivery, and then return to the original workstation. Each individual trip may take only a few minutes, but the accumulated time across repeated trips, multiple employees, and several shifts can become significant.
The existing draft makes this point particularly well: every minute an operator spends pushing a trolley is time that cannot simultaneously be spent assembling products, inspecting quality, or operating production equipment.
Necessary Movement Does Not Have to Mean Manual Movement
Material transportation cannot simply be removed from manufacturing. Components still have to reach production. WIP still has to move to the next operation. Finished goods still have to reach storage.
The opportunity therefore lies in determining which material movements genuinely require human involvement and which can be automated.
This is one of the strongest use cases for Autonomous Mobile Robots for Material Handling.
Instead of repeatedly assigning employees to predictable point-to-point movements, an AMR can perform predefined transportation missions between warehouses, kitting stations, production lines, inspection areas, testing stations, and finished-goods locations.
The operational objective is therefore not:
“How do we eliminate material movement?”
It is:
“How do we eliminate unnecessary human involvement in repetitive material movement?”
That difference is central to understanding the role of AMRs for factory material handling.
Moving Employees Towards Higher-Value Manufacturing Activities
Reducing repetitive transportation can allow production personnel to spend more of their working time on activities directly connected to manufacturing performance.
Depending on the facility and role, these can include assembly, equipment operation, quality inspection, testing, production monitoring, troubleshooting, preventive maintenance, process improvement, inventory control, and other skilled activities.
This creates a more useful way of evaluating the ROI of Autonomous Mobile Robots for Material Handling. The value is not limited to calculating how many trolley movements a robot can complete.
Manufacturers should also consider questions such as:
- How many employee-hours are currently consumed by internal transportation?
- How frequently do production personnel leave their assigned areas to move material?
- Which repetitive transport routes occur every shift?
- Where do production lines regularly wait for replenishment?
- Which movements involve long walking or trolley-pushing distances?
- Which tasks could be transferred to AMRs without disrupting the manufacturing process?
Answering these questions helps identify where manufacturing material handling automation can produce meaningful operational improvements.
The Material-Movement Challenge in Indian Manufacturing
Indian manufacturing is becoming more automated across electronics and EMS, automotive components, pharmaceuticals, engineering, consumer goods and other industrial sectors. Manufacturers are investing in advanced production equipment, digital monitoring and Industry 4.0 technologies to improve capacity, quality and productivity.
However, automation inside a production line does not automatically create an automated factory.
Materials still need to move between warehouses, kitting areas, production lines, inspection stations, testing areas, packaging and finished-goods storage. As production volumes increase, the frequency of these movements increases as well.
This is where Autonomous Mobile Robots for Material Handling can address an important gap. Instead of production and warehouse personnel repeatedly transporting components, WIP, trolleys and finished goods manually, suitable point-to-point movements can be incorporated into an automated intralogistics workflow.
For Indian manufacturers, this becomes particularly relevant when expanding production capacity. Increasing output without improving internal logistics can simply transfer the bottleneck from manufacturing equipment to material movement.
Scaling Production Without Scaling Manual Transportation
Higher production volumes create more component replenishment, WIP transfers, packaging-material movement and finished-goods transportation.
If every increase in production requires a corresponding increase in manual trolley movement, walking and logistics coordination, internal transportation can become increasingly difficult to manage efficiently.
Autonomous Mobile Robots for Material Handling in India provide manufacturers with a more scalable approach. Frequently repeated routes—such as warehouse-to-production, kitting-to-line, production-to-testing and packaging-to-warehouse—can be evaluated for automation while employees remain focused on activities requiring judgement and technical skill.
The objective is therefore not simply to reduce manpower. It is to achieve better workforce utilisation by separating repetitive transportation from higher-value manufacturing activities.
Production operators can remain focused on assembly and equipment operation. Quality teams can concentrate on inspection. Warehouse personnel can manage inventory and material preparation rather than spending excessive time transporting it.
Moving Towards Connected Factory Intralogistics
The next stage of manufacturing automation is also about making material movement more predictable and connected.
Manual transportation is often reactive: a material requirement arises, someone communicates it, an employee becomes available, and the material is eventually moved.
With Autonomous Mobile Robots for Material Handling, transportation can become a structured workflow in which missions are assigned, monitored and recorded. When connected with broader factory systems, AMRs can also become part of a more integrated smart manufacturing and intralogistics strategy.
The transition can be understood simply as:
Manual trolley movement → Autonomous material transport
Reactive delivery → Planned material flow
Operator-dependent movement → System-driven missions
Disconnected transportation → Connected factory intralogistics
For Indian manufacturers pursuing lean manufacturing, higher productivity and Industry 4.0, the real value of AMRs therefore lies in making the movement between production processes as organised as the production processes themselves.
How Autonomous Mobile Robots Work in Manufacturing
Unlike conventional material-handling equipment that may depend on fixed tracks or predefined physical guidance infrastructure, Autonomous Mobile Robots for Material Handling use onboard sensors, mapping and navigation technologies to move through their operating environment.
Modern AMRs commonly combine technologies such as LiDAR, cameras, sensors and SLAM (Simultaneous Localization and Mapping) to understand their surroundings and determine their position within a mapped facility. The existing draft correctly identifies SLAM as one of the core technologies enabling AMRs to map an environment while continuously estimating their own location.
In practical terms, an AMR workflow can be understood as:
Map → Localise → Detect → Navigate → Transport → Deliver
As the robot moves, its sensors help identify people, equipment and other obstacles. Instead of relying entirely on one fixed physical route, the AMR can use its digital map and navigation system to determine an appropriate path to its destination.
This capability is particularly useful in dynamic manufacturing environments where pedestrian traffic, trolleys and temporary obstacles may change throughout the day.
From Individual Robots to Connected Material Handling
The value of Autonomous Mobile Robots for Material Handling increases when transportation becomes part of a coordinated factory workflow.
Rather than treating every movement as an isolated robot trip, manufacturers can define pickup points, delivery locations, recurring missions and material-handling workflows. With appropriate integration, AMRs can also interact with broader manufacturing and warehouse systems.
The result is a transition from simply moving material autonomously to managing internal logistics as a connected process.
Typical Material Flow Inside an EMS Manufacturing Plant
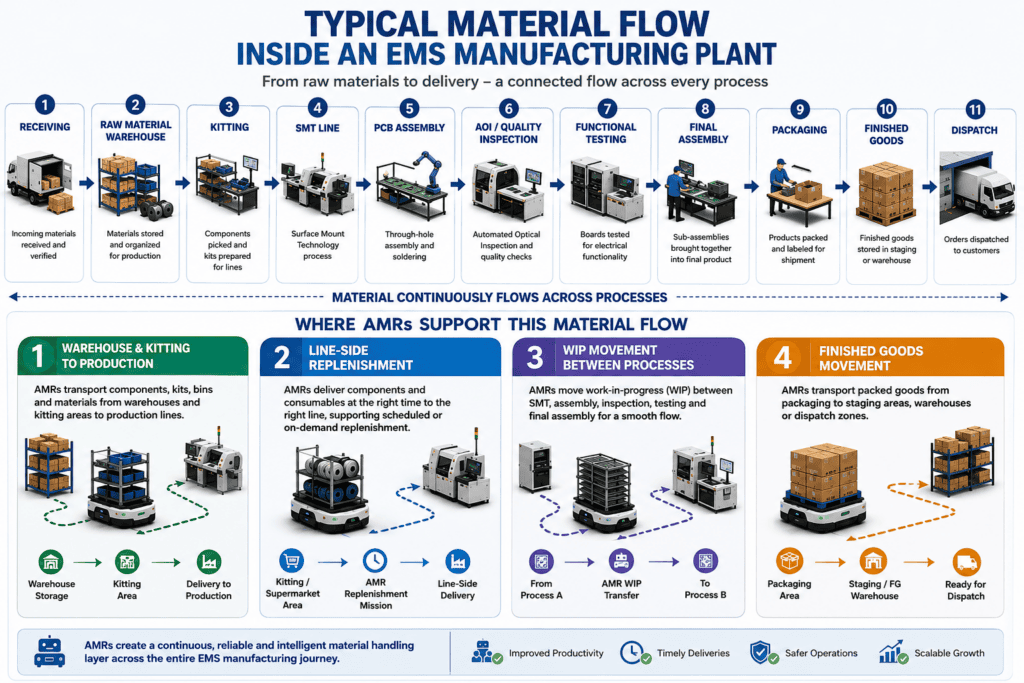
Electronics and EMS manufacturing provide a particularly useful example because material passes through several interconnected stages before a finished product is ready for dispatch.
A typical flow may include:
Receiving → Raw Material Warehouse → Kitting → SMT Line → PCB Assembly → AOI/Quality Inspection → Functional Testing → Final Assembly → Packaging → Finished Goods → Dispatch
The current draft identifies these stages and explains how material continuously moves between them.
This entire sequence should eventually be presented as a single material-flow infographic rather than a long text section.
Where Can AMRs Support This Material Flow?
The most useful applications can be consolidated into four areas.
Warehouse and Kitting to Production
Components, production kits, bins and other materials can be transported from storage and kitting areas to designated production locations.
In high-volume operations, these repeated routes can represent a significant portion of internal transportation.
Line-Side Replenishment
Production lines require components and consumables to arrive at appropriate intervals. AMRs for material handling in manufacturing can support scheduled or system-triggered replenishment workflows, reducing dependence on employees making repeated delivery trips.
WIP Movement Between Processes
Work-in-progress frequently needs to move from one production stage to another—for example, between manufacturing, inspection, testing and final assembly.
Automating suitable WIP routes can help create a more consistent material flow between otherwise automated processes.
Finished Goods Movement
Once production and packaging are complete, AMRs can also support suitable movements towards staging areas, warehouses or subsequent internal logistics points.
The larger objective is to create a continuous material-handling layer connecting the factory:
Warehouse → Production → Quality → Testing → Packaging → Finished Goods
What Changes After Material Handling Is Automated?
The value of Autonomous Mobile Robots for Material Handling should be measured by the improvement they create in the overall manufacturing workflow—not simply by the number of trips completed.
More Productive Use of Workforce
When repetitive transportation is automated, production and warehouse personnel can spend more time on manufacturing, inspection, inventory control, maintenance and other activities requiring human involvement.
This directly addresses the excessive non-value-added activities discussed earlier in the article.
More Predictable Material Flow
A manually requested delivery can depend on employee availability. An automated transport mission can be assigned and tracked as part of a defined workflow.
This creates greater predictability for recurring movements such as line-side replenishment and WIP transfers.
Better Visibility of Internal Logistics
Manual trolley movements can be difficult to measure systematically.
AMR-based logistics can provide greater visibility into assigned missions, robot status and completed movements. With appropriate system integration, internal transportation can become part of the factory’s wider digital operations.
Easier Scaling of Repetitive Logistics
As production grows, material movement grows with it.
A properly planned AMR deployment can be expanded through additional missions or robots rather than relying exclusively on proportionately increasing manual transportation.
The operational progression can therefore be summarised as:
Manual Movement → Automated Missions → Coordinated Fleet → Connected Intralogistics AMR vs AGV: What Is the Difference?
AMRs and Automated Guided Vehicles (AGVs) both automate material transportation, but they should not be treated as identical technologies.
Traditional AGVs generally operate along predetermined routes and may depend on infrastructure such as magnetic strips, wires, reflectors or other guidance methods, depending on the system.
Autonomous Mobile Robots for Material Handling generally use digital maps, sensors and autonomous navigation to understand their surroundings and determine their route.
The practical distinction is flexibility.
Where an AGV system is designed around a defined path, an AMR can be more adaptable to environments in which routes and obstacles change. This can make AMRs particularly useful in factories where production layouts, workstations or material-flow requirements evolve over time.
The existing draft makes this distinction clearly by contrasting fixed AGV routes with the digital mapping and dynamic navigation used by AMRs.
However, the choice should depend on the actual application. Manufacturers should evaluate load, route, traffic, workflow, infrastructure and integration requirements before deciding which automation technology is appropriate.
AMR Solutions for Different Material-Handling Requirements
There is no single AMR configuration suitable for every factory movement. Payload, trolley type, load dimensions, pickup method, route and operating environment all influence robot selection.
For the current blog, this section should focus only on the three relevant solutions rather than becoming a long product catalogue.
PUDU T300 — Flexible Trolley and Material Transportation
The PUDU T300 is particularly relevant to repetitive trolley-based internal logistics.
Depending on the deployment and trolley configuration, potential applications include:
- warehouse-to-production transportation;
- line-side replenishment;
- WIP transfer;
- movement of returnable racks or containers; and
- finished-goods transportation.
An important capability identified in the existing article is autonomous trolley hooking, transportation and release, which can reduce the need for manual trolley handling during repetitive missions.
The PUDU T300 therefore fits applications where manufacturers want Autonomous Mobile Robots for Material Handling to work with suitable trolley-based workflows rather than simply carrying material on the robot itself.
PUDU T600 — Higher-Payload Material Movement
Where manufacturing operations involve heavier loads, the PUDU T600 can address higher-payload internal logistics requirements.
Its role should be explained around the application rather than filling the section with technical specifications: heavier materials, larger loads and industrial transportation requirements where a higher-capacity AMR is appropriate.
Robot selection should nevertheless be based on the actual payload, dimensions, loading method, route and operating environment.
FlashBot Max — Controlled Internal Transportation
FlashBot Max addresses a different requirement: enclosed and controlled transportation.
Within appropriate manufacturing environments, this may be useful where sensitive components, instruments, samples, documents or other materials need to move within an enclosed robot rather than on an open trolley or platform.
Together, these solutions demonstrate an important point: AMR selection should follow the material-handling requirement.
Workflow first. Robot second.
Deploying Autonomous Mobile Robots in Indian Manufacturing Facilities
Successful AMR deployment should begin with the material flow—not the robot specification sheet.
Before selecting an Autonomous Mobile Robot for Material Handling in India, manufacturers should examine the actual operating environment, including:
- material type and payload;
- trolley or carrier design;
- frequency of movements;
- pickup and drop-off points;
- aisle dimensions and floor conditions;
- pedestrian and vehicle traffic;
- charging requirements;
- existing manufacturing workflows; and
- integration requirements.
A practical deployment process can be structured as:
Site Study → Material Flow Mapping → Identify Automation Tasks → Select AMR → Map Routes → Pilot → Validate → Scale
This is also where a local robotics implementation partner becomes important.
For Indian manufacturers, Autofina Robotics can support areas such as site assessment, workflow analysis, mapping, robot selection, deployment, integration, commissioning, training and after-sales support. The existing draft already identifies these stages as important parts of AMR implementation.
The emphasis in this section should remain on successful implementation, rather than turning it into a promotional company profile.
Conclusion
Efficient manufacturing depends on much more than advanced production equipment. The ability to move materials quickly, safely, and accurately between every stage of production has become a defining factor in achieving higher productivity, reduced operating costs, and consistent manufacturing performance.
As factories continue to embrace Industry 4.0 and lean manufacturing principles, Autonomous Mobile Robots (AMRs) for Material Handling are transforming the way internal logistics is managed. By automating repetitive transportation tasks such as raw material delivery, SMT line replenishment, Work-in-Progress (WIP) movement, finished goods transport, and trolley handling, AMRs help eliminate production bottlenecks while enabling employees to focus on higher-value activities.
Unlike traditional transportation methods, modern AMRs combine intelligent navigation, real-time obstacle avoidance, fleet coordination, and seamless integration with digital manufacturing systems to create a more connected and responsive production environment. Their flexibility allows manufacturers to adapt quickly to changing production demands without extensive infrastructure modifications, making them a practical and future-ready investment.
Solutions such as the Pudu T300 for intelligent trolley movement, the Pudu T600 for heavy-duty material transport, and the FlashBot Max for secure autonomous delivery demonstrate how industrial AMRs can address diverse logistics requirements across EMS manufacturing, automotive, pharmaceuticals, precision engineering, and other industrial sectors.
At Autofina Robotics, we are committed to helping manufacturers unlock the full potential of industrial automation. From evaluating existing material handling processes to deploying and supporting advanced Pudu Robotics solutions, our team works closely with customers to implement AMR systems that align with their operational goals and long-term growth strategies.
As manufacturing continues to evolve, investing in intelligent internal logistics is no longer simply about reducing manual effort—it is about building a smarter, safer, and more resilient factory capable of meeting the demands of tomorrow’s production landscape.
As the official Pan-India distributor for Pudu Robotics, Autofina Robotics brings PUDU’s advanced robotic solutions to manufacturers across India, supported by local consultation, deployment, integration, training and after-sales assistance.
Request a Live Demo
Tell us about your facility and cleaning challenges. We provide Pan India support and installations. Our team will propose routes, coverage estimates, and ROI.
Email: [email protected]
Phone: +91 98192 22944 | +91 98238 30979